
Power Cube Intake
2018 FIRST Robotics Competition
Mechanical Skills Used:
CAD 3D Modeling, Prototyping, Iterative Design, FDM 3D Printing, Mechanical Assembly
Electrical and Programming Skills Used:
N/A
Software Used:
Solidworks
The challenge for the 2018 FRC competition involved the manipulation of a 13" Power Cube (shown below). The best robots needed to have the ability to intake the cube from any orientation.
I lead a team through the design, prototyping, iteration and fabrication of this manipulator. The soul design criteria in my mind was that the manipulator should be able to quickly and efficiently intake a cube from any angle.
Starting off with a simple layout sketch I worked out the geometry of a spring loaded intake that utilizes compression and rotary motion in order to intake and reorient a cube. Following this, I fabricated a rough prototype using the layout sketch as a basis for dimensions, 2x1 extrusion, power drills as power, and surgical tubing as the spring component.
Promising tests lead to the design of the iteration shown below. The framework is 1/4" aluminum plate with lightning patterns, powered by 5:1 gear ratio VersaPlanetary gearboxes and spring loaded with 4" BIMBA piston actuators.
To keep the intake compact when the robot is in motion, I worked out the geometry to raise and lower the entire assembly using 8" 120-pound force pistons.

Layout Sketch
Mathematical Geometry behind the Intake.
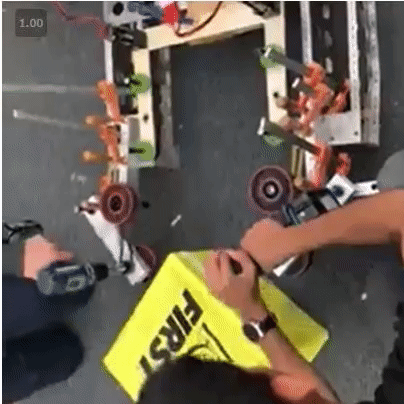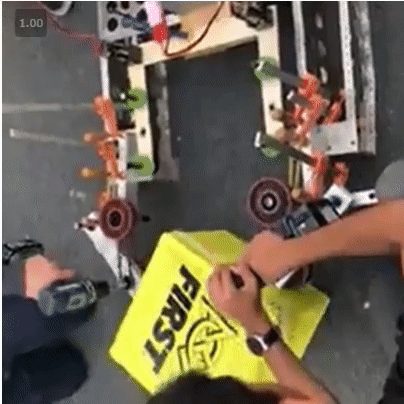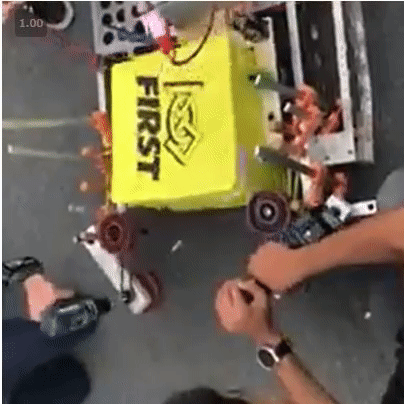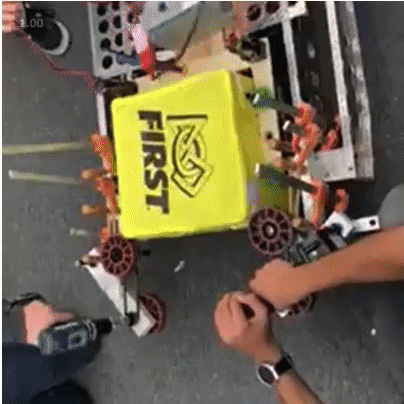
Physical Prototype
Prototype created using 2x1, wood and drill motors to verify CAD geometry.

Final Design
Isometric View

Final Design
Top View
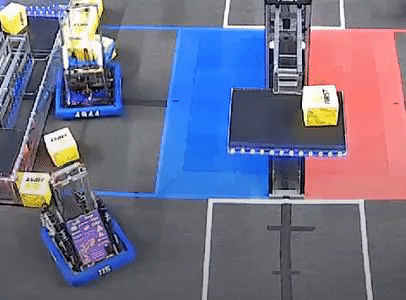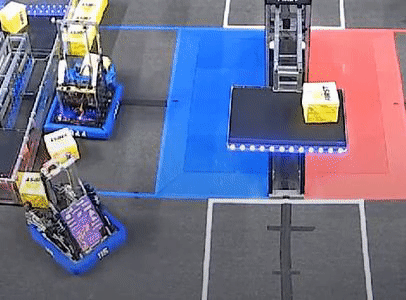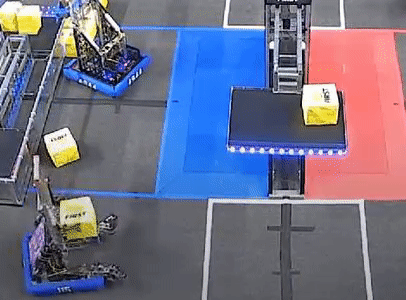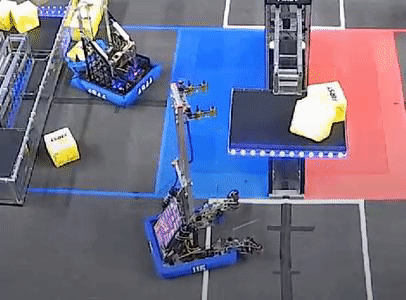
Robot View
Intake interfaces with the robot elevator and carriage.

Power Cube
The competitoin utilized a 13" by 13" Milk crate as the gamepiece.